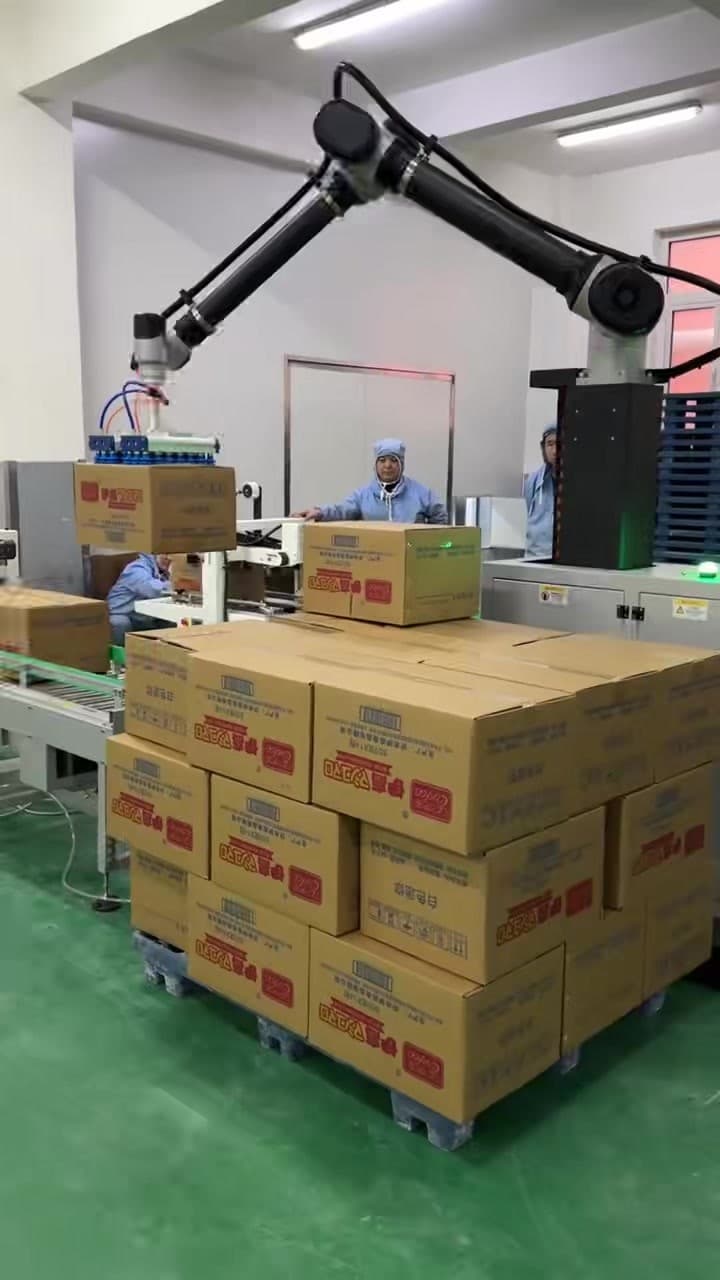
 00:03
01
Carton pickup and transfer
The end-of-arm pickup tooling contacts the top of a carton, lifts it and transfers it to an operating position.
Application case · Carton palletizing
A lifting workstation for carton handling and pallet operations
This video shows a CR50L carton palletizing application with a lifting column. The robot uses carton pickup tooling for handling and transfer around the conveyor and pallet work areas. The footage also shows a multi-layer carton stack and a workstation touchscreen.
This application uses the CR50L lifting configuration, with carton pickup tooling, conveyor equipment and pallet positions. View the CR50L-1900 product page for catalog specifications and the dimensional drawing.
Project overview
Cartons require repeated pickup, movement and placement between conveying and pallet work areas. This workstation brings together a collaborative robot on a lifting column, carton pickup tooling and local operating equipment. The video records carton lifting and transfer, together with robot handling around a multi-layer pallet stack.
00:0301
The end-of-arm pickup tooling contacts the top of a carton, lifts it and transfers it to an operating position.
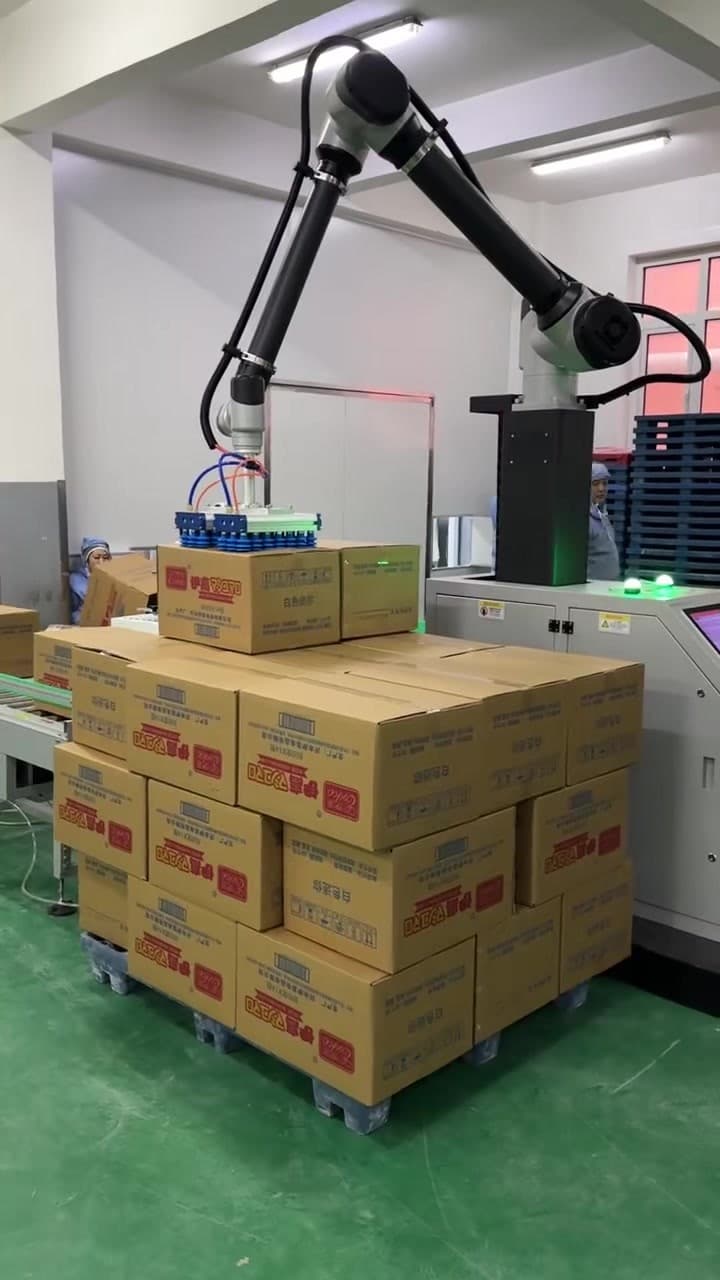 00:06
02
The robot brings the carton to the pallet area, where multiple carton layers are already present, and connects the pickup and placement movements.
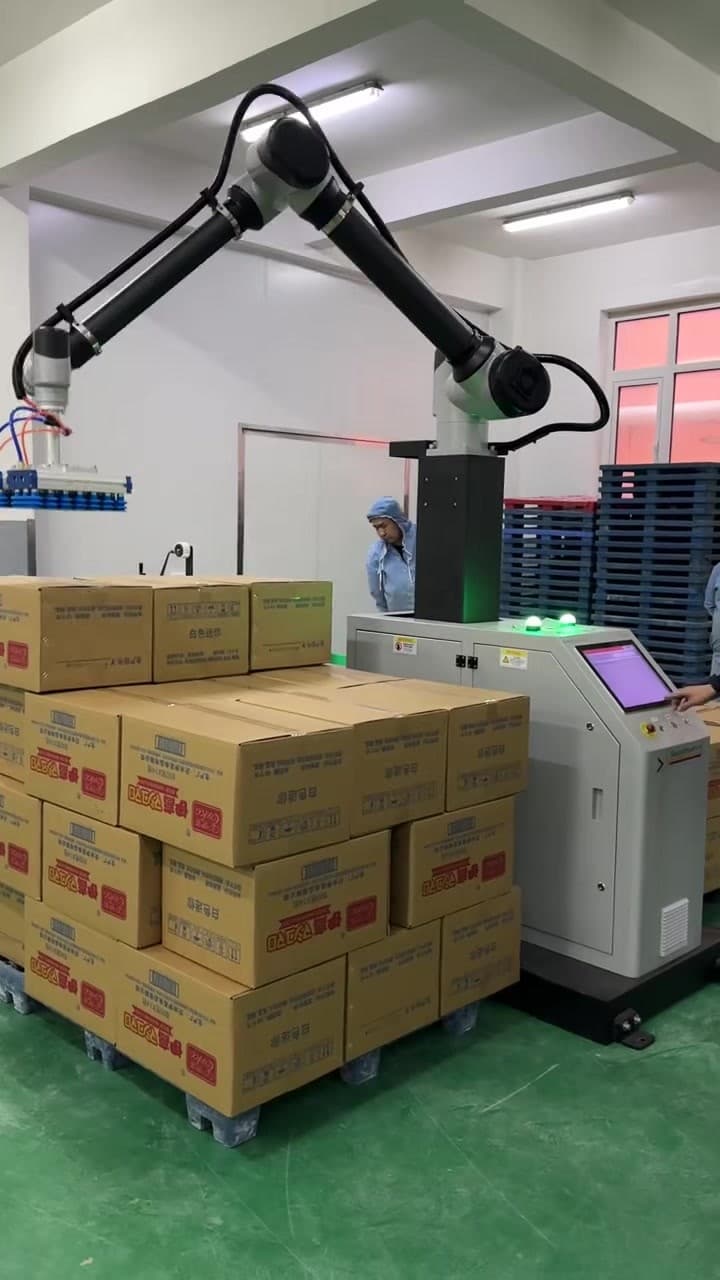 00:18
03
The robot is mounted on a lifting column next to the workstation cabinet, with conveyor equipment and pallet positions arranged around the cell.
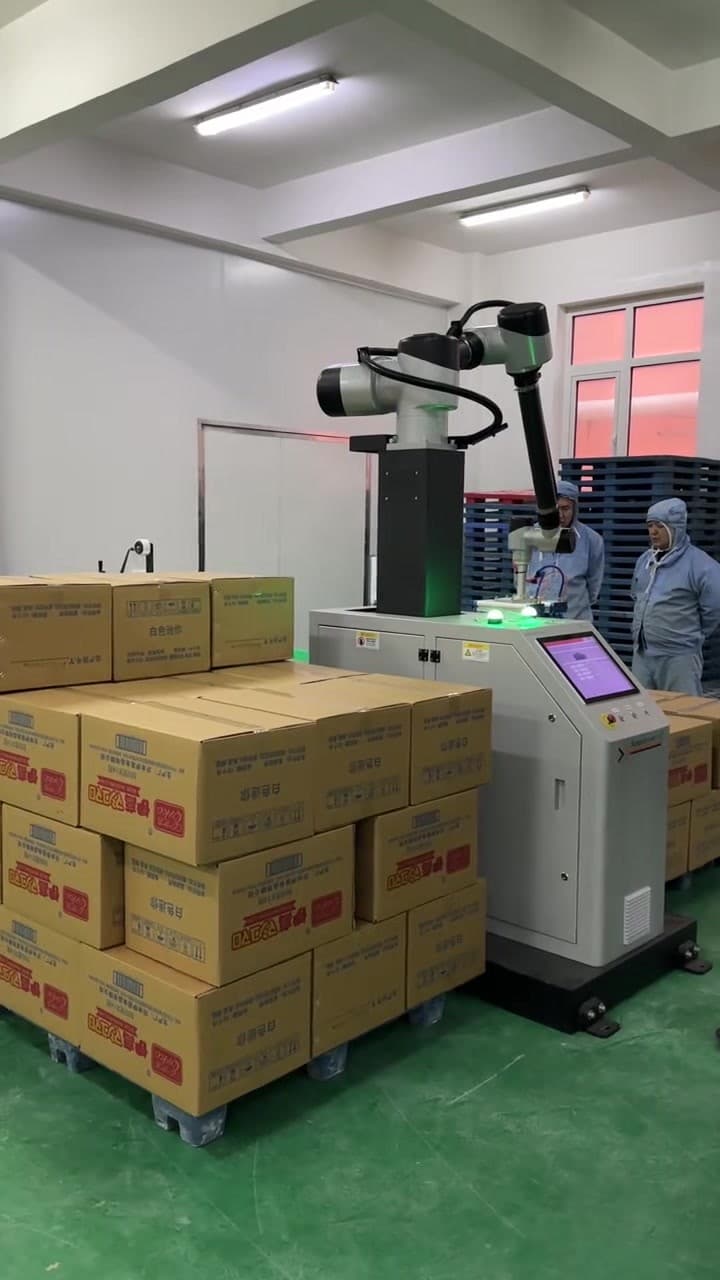 00:30
04
The cabinet has a touchscreen panel and visible status indicators. Robot movements connect the adjacent carton handling positions.
Send carton dimensions and weight range, target hourly output, conveyor pickup height, pallet size and pattern, target stack height and a layout to review the lift configuration, tooling and working positions.