 00:01.5
01
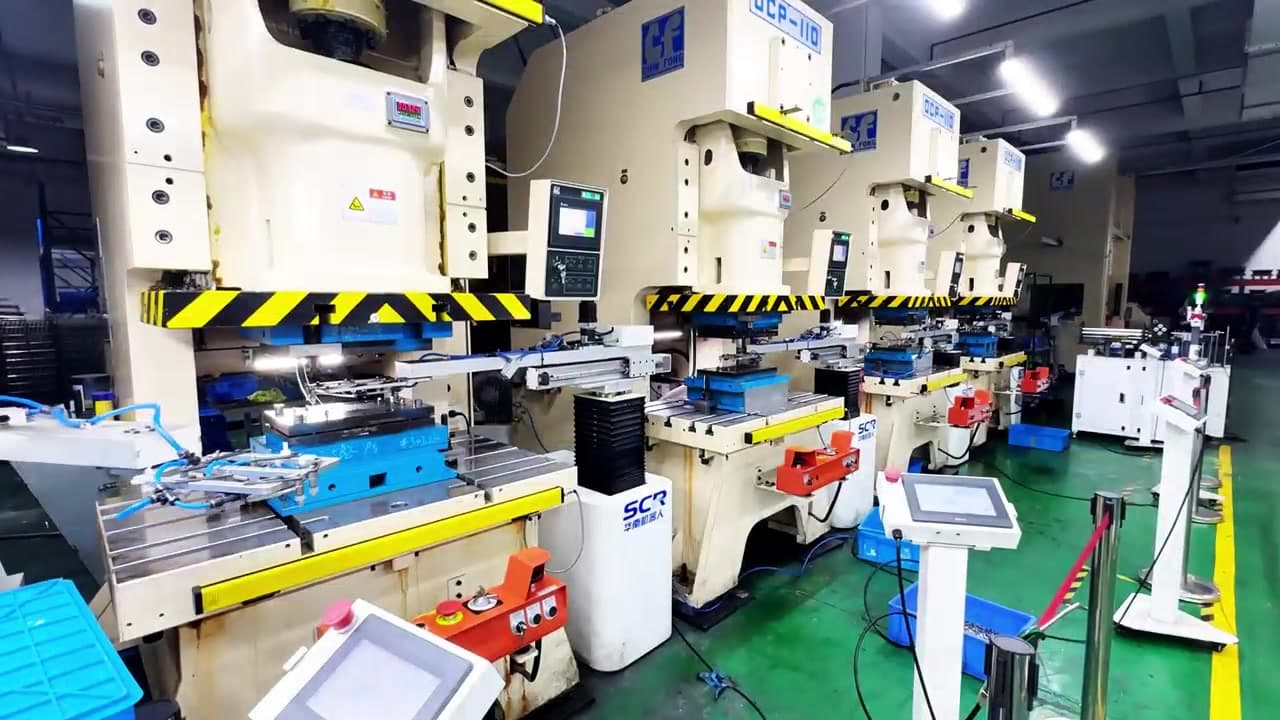
A multi-press layout
Presses are arranged along the line, with transfer robots between stations and touchscreen panels beside the equipment.
Application case · Metal stamping
Part handling and transfer across a multi-press stamping line
This project places STC10 stamping robots between presses to handle parts and transfer them between operations. Robot movements alternate with press cycles, connecting material flow across multiple stamping stages.
The footage shows presses arranged along a production line, inter-press transfer robots, dedicated end-of-arm tooling and press-side touchscreen panels. Robot travel, tooling and handling paths are matched to the parts, dies and site layout.
Project overview
Parts moving through successive stamping operations must be removed, transferred and placed at the next station. At this site, robots positioned along the press line move their tooling into the die areas for part handling and withdraw before subsequent press movements. The video shows handling, transfer and press cycles working in sequence across the line.
00:01.501
Presses are arranged along the line, with transfer robots between stations and touchscreen panels beside the equipment.
 00:02.5
02
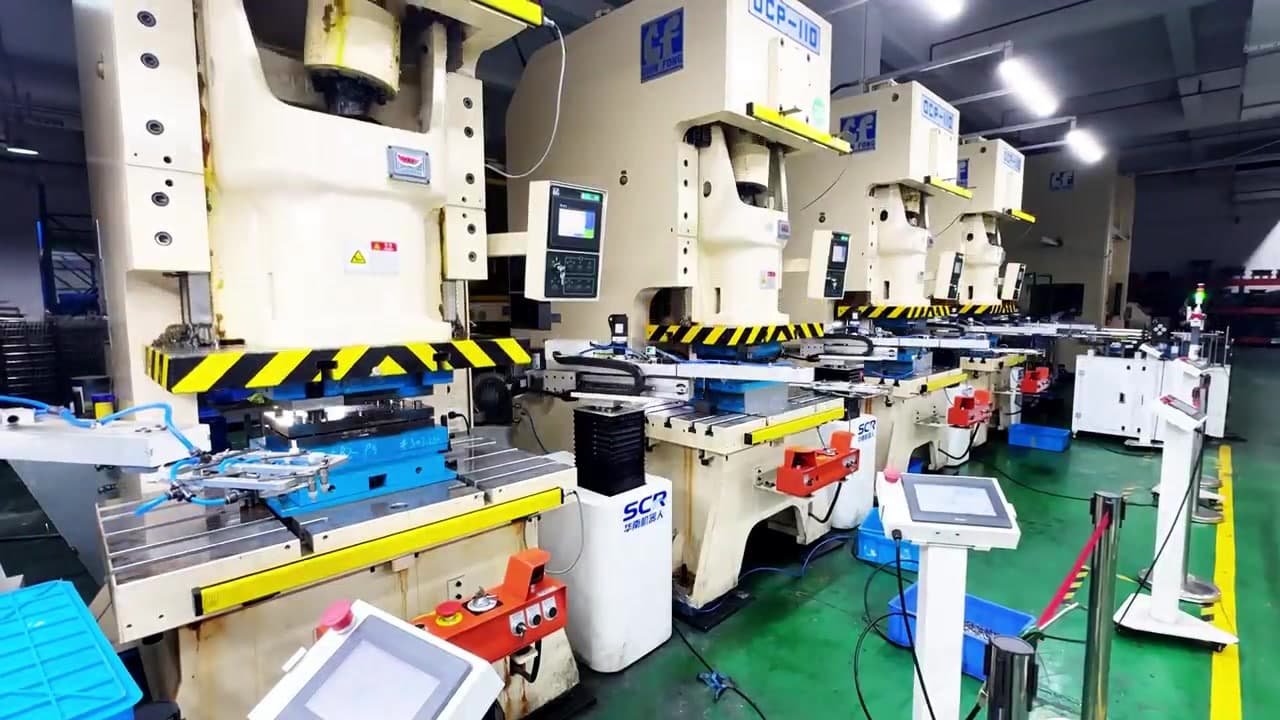
The robots move parts between adjacent die areas to connect successive stamping operations.
 00:05.5
03
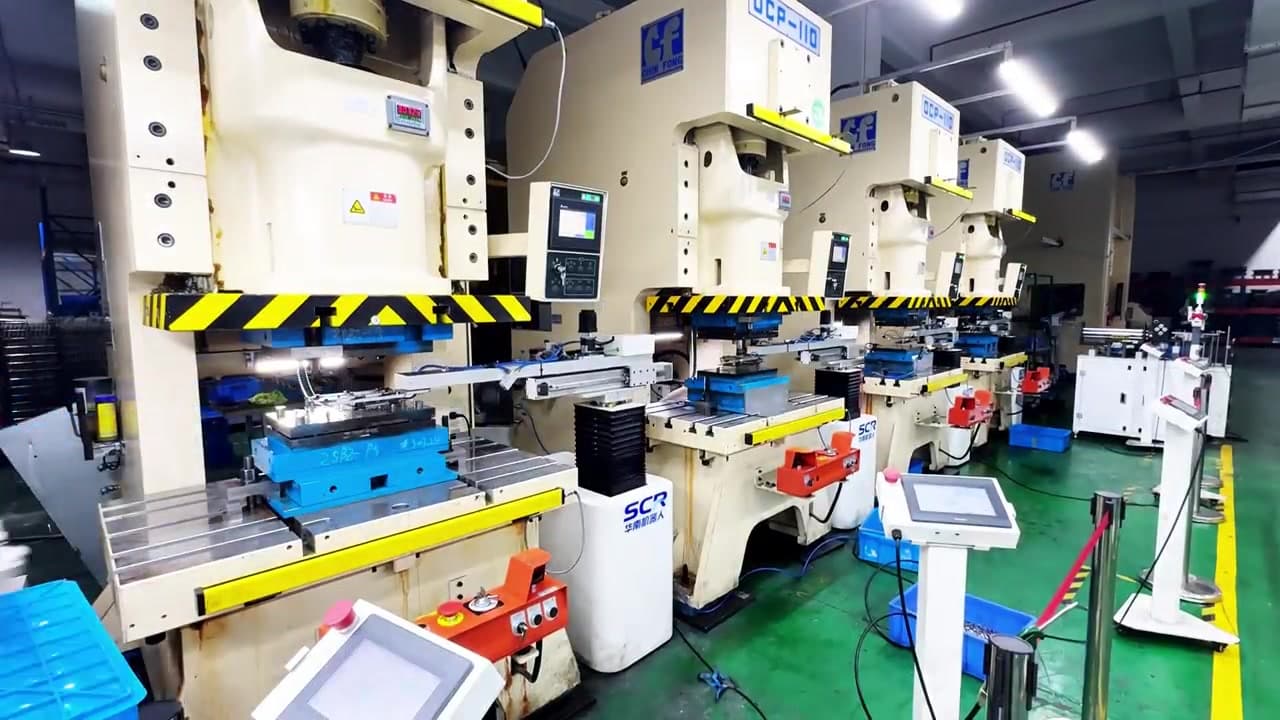
End-of-arm tooling enters the die working area to handle parts, following a path planned around the die positions.
 00:08.5
04
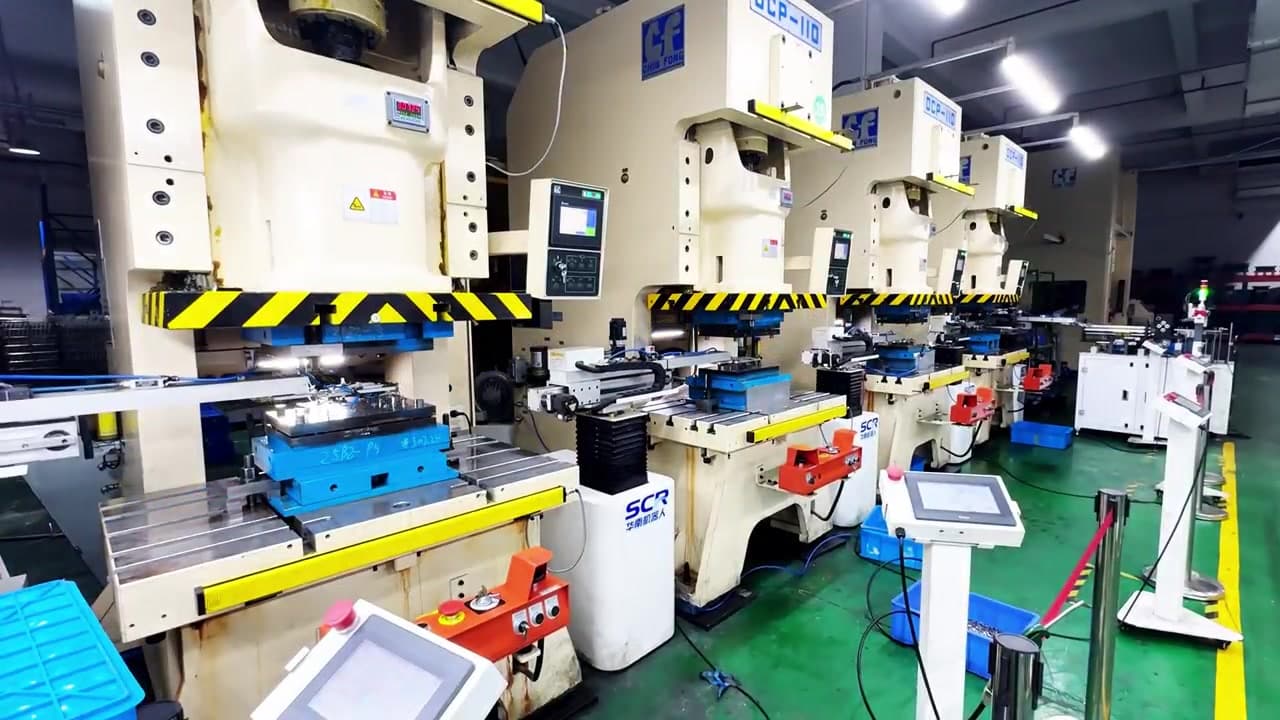
After the tooling withdraws from the die area, the press performs its subsequent movement. The next handling and transfer sequence follows die opening.
Send part drawings or photos, unit weight, operation sequence, die opening clearance, press spacing, site layout and target cycle time. These inputs support review of robot travel, tooling and station-to-station transfer.