 00:08
01
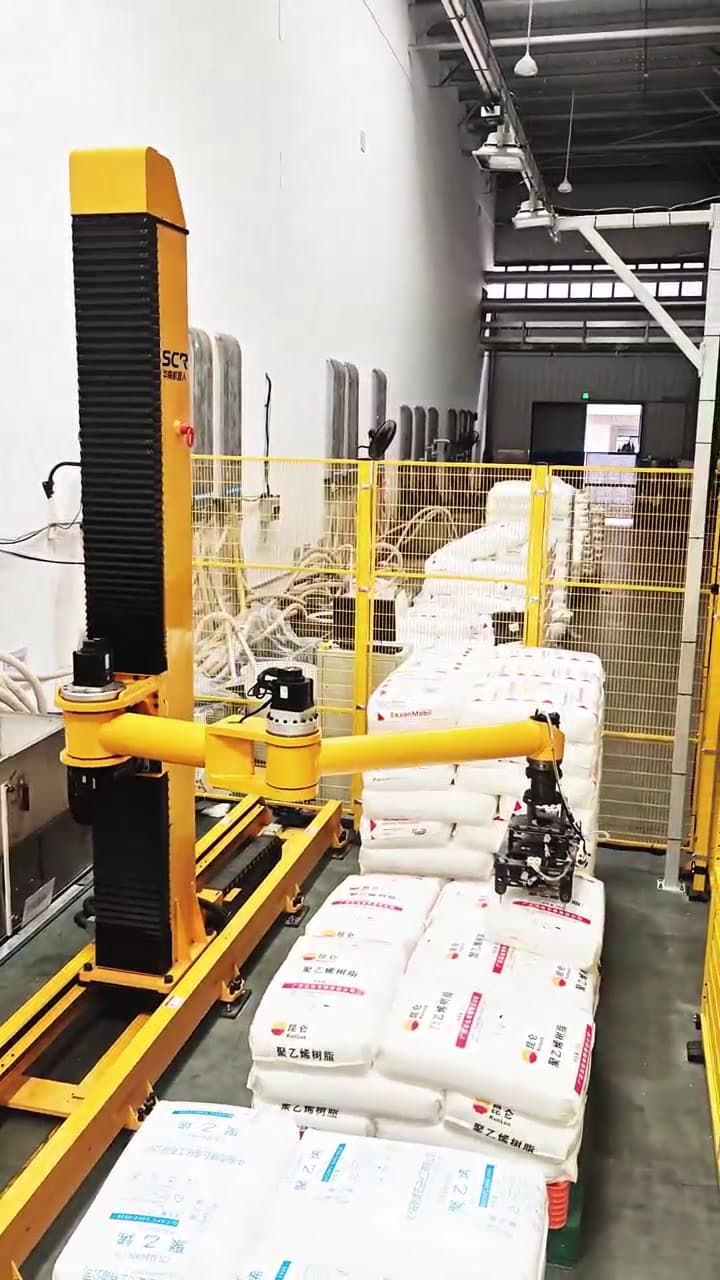
Pick up a bag
The robot moves to the pickup position. Its end-of-arm tooling engages the bag and lifts it from the stack.
Customer project · Bag opening and feeding
A customer-specific linear track installation
This project combines an SCH100 robot with a custom linear track, dedicated bag-handling tooling and a bag-opening station. The cell connects bag pickup, transfer, material discharge and subsequent packaging-bag transfer.
The video shows a customer-specific installation with a linear track. The standard SCH100 configuration does not include a linear track. The track shown here was configured for this customer's site requirements.
Project overview
At this site, stacked bags are positioned alongside the bag-opening and feeding equipment. The robot picks up a bag from the stack, transfers it to the feeding station, and then moves the packaging bag to a separate receiving position. The project brings the robot, linear track, dedicated tooling and feeding station together as one bag-handling cell.
00:0801
The robot moves to the pickup position. Its end-of-arm tooling engages the bag and lifts it from the stack.
 00:14
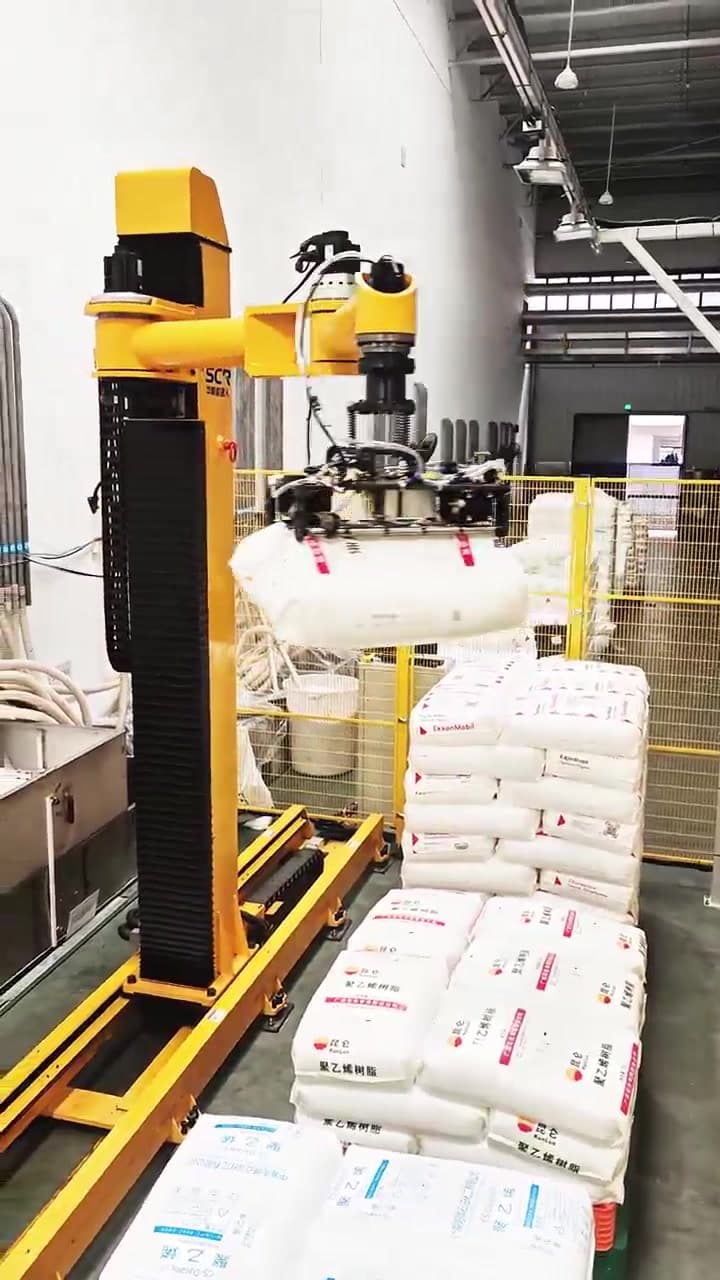
02
Vertical motion, rotation and linear-track travel bring the bag to the opening and feeding area.
 00:25
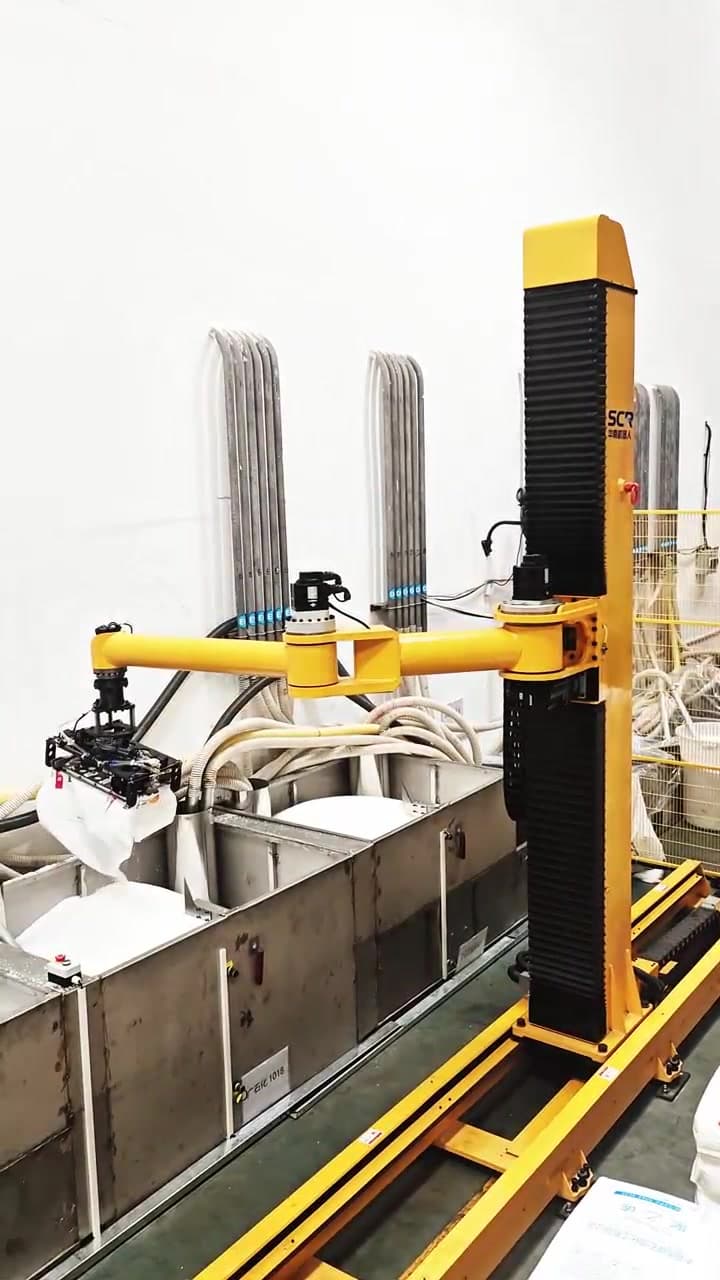
03
The bag is opened and its contents are discharged into the receiving unit below.
 00:40
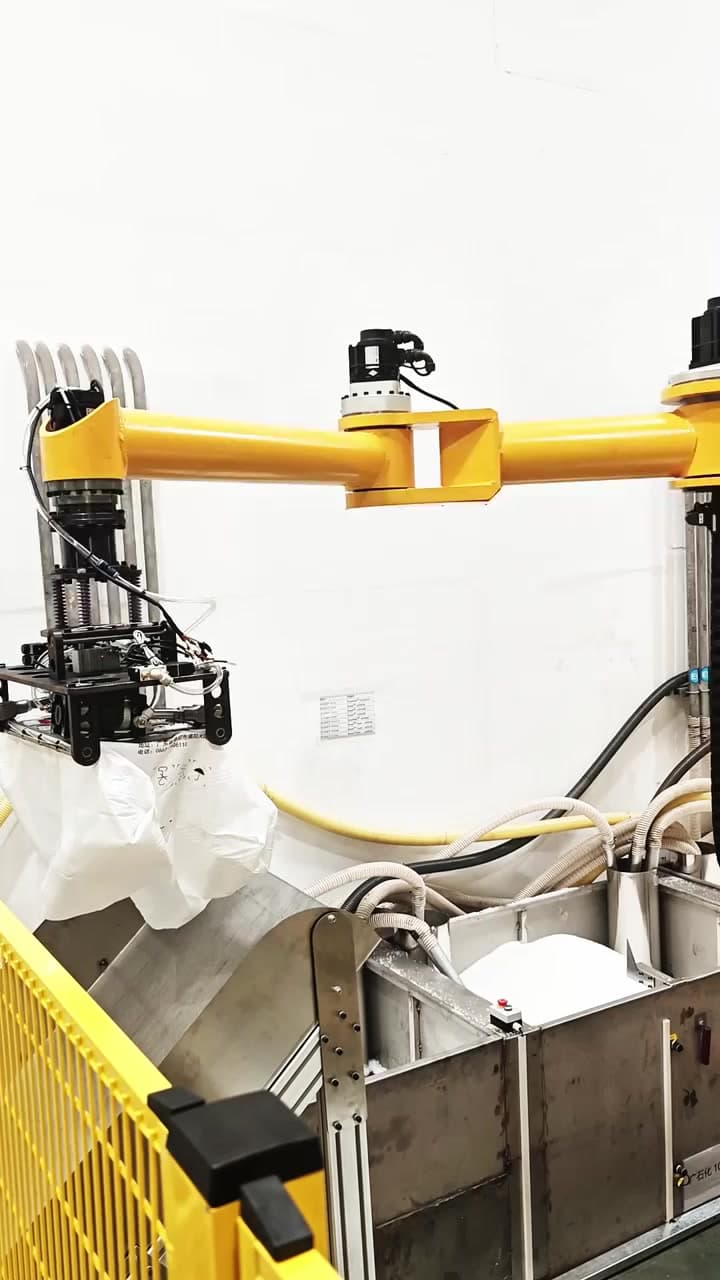
04
After discharge, the robot moves the packaging bag to an adjacent receiving position for subsequent collection.
Send bag dimensions, packaging material, unit weight, stack and inlet positions, target throughput and a site layout. These inputs help us assess SCH100 suitability and whether a linear track or other project-specific equipment is needed.